Vítor Fonseca

Vítor Fonseca

Robotics MSc student @ TUM | Perception, Control, Prototyping & Systems Integration (experience in UAVs, AMRs, and AVs). Currently building an autonomous fixed-wing drone for GNSS denied and low visibility navigation using ROS 2, SLAM, and AI.

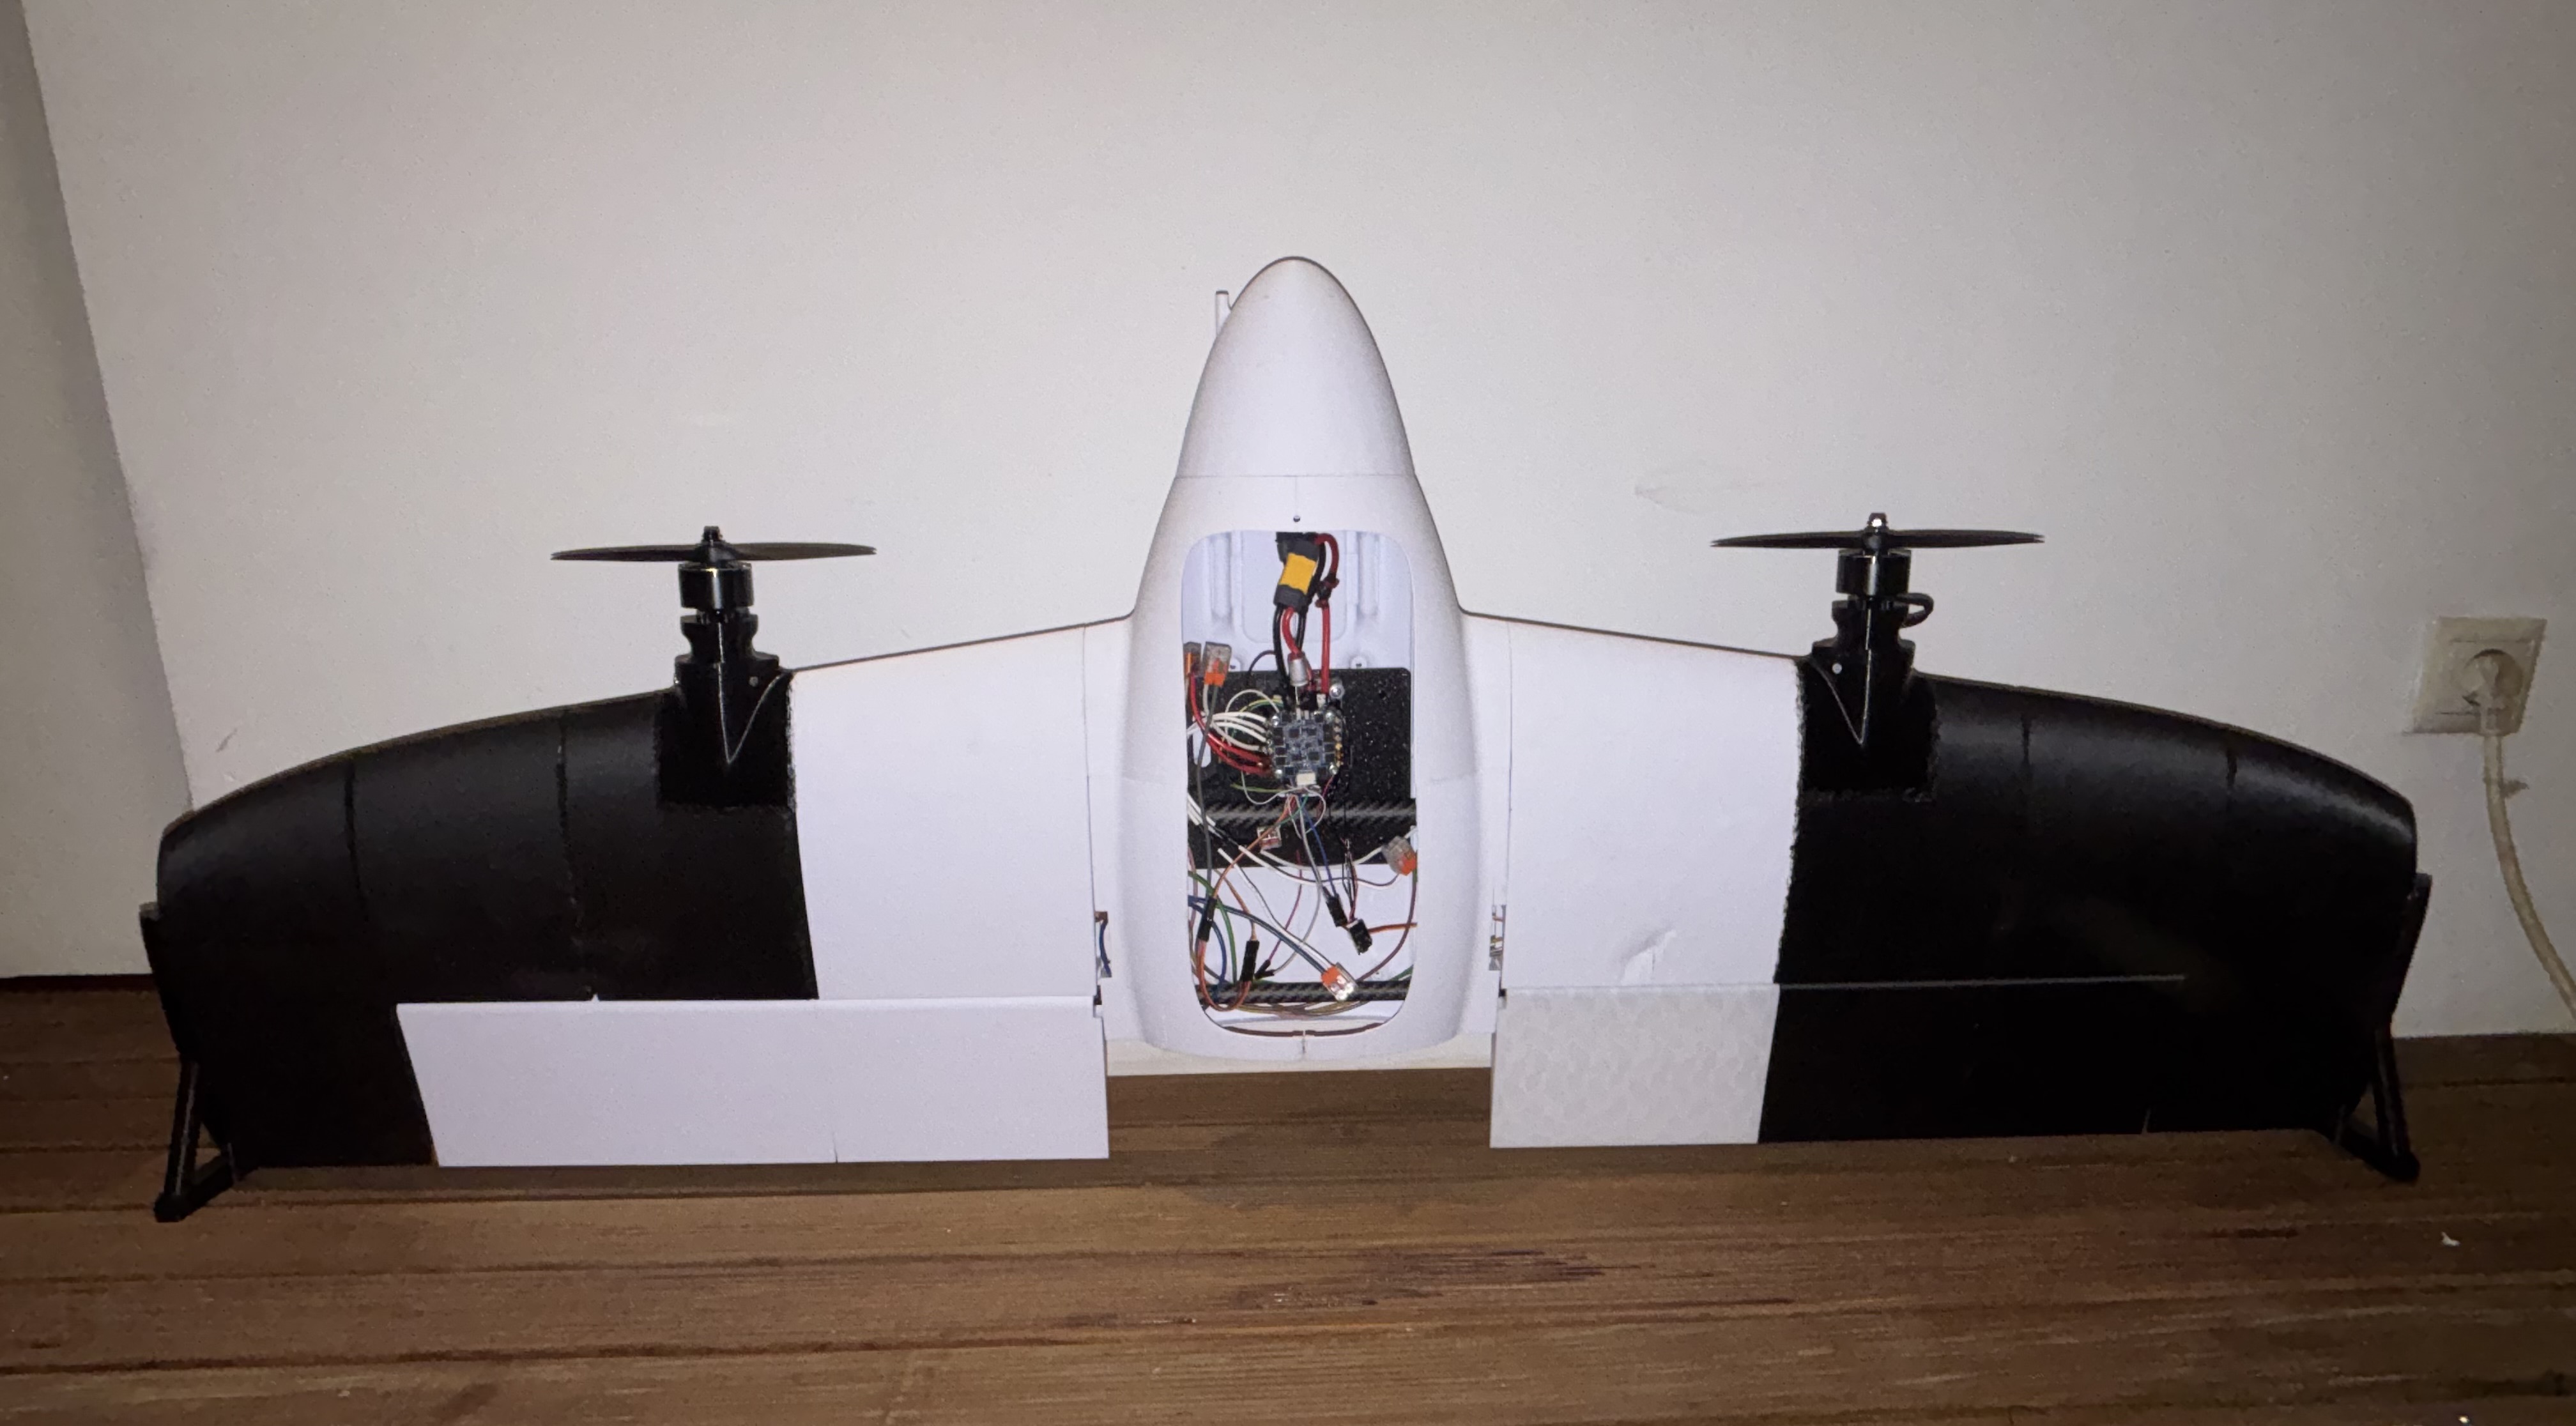
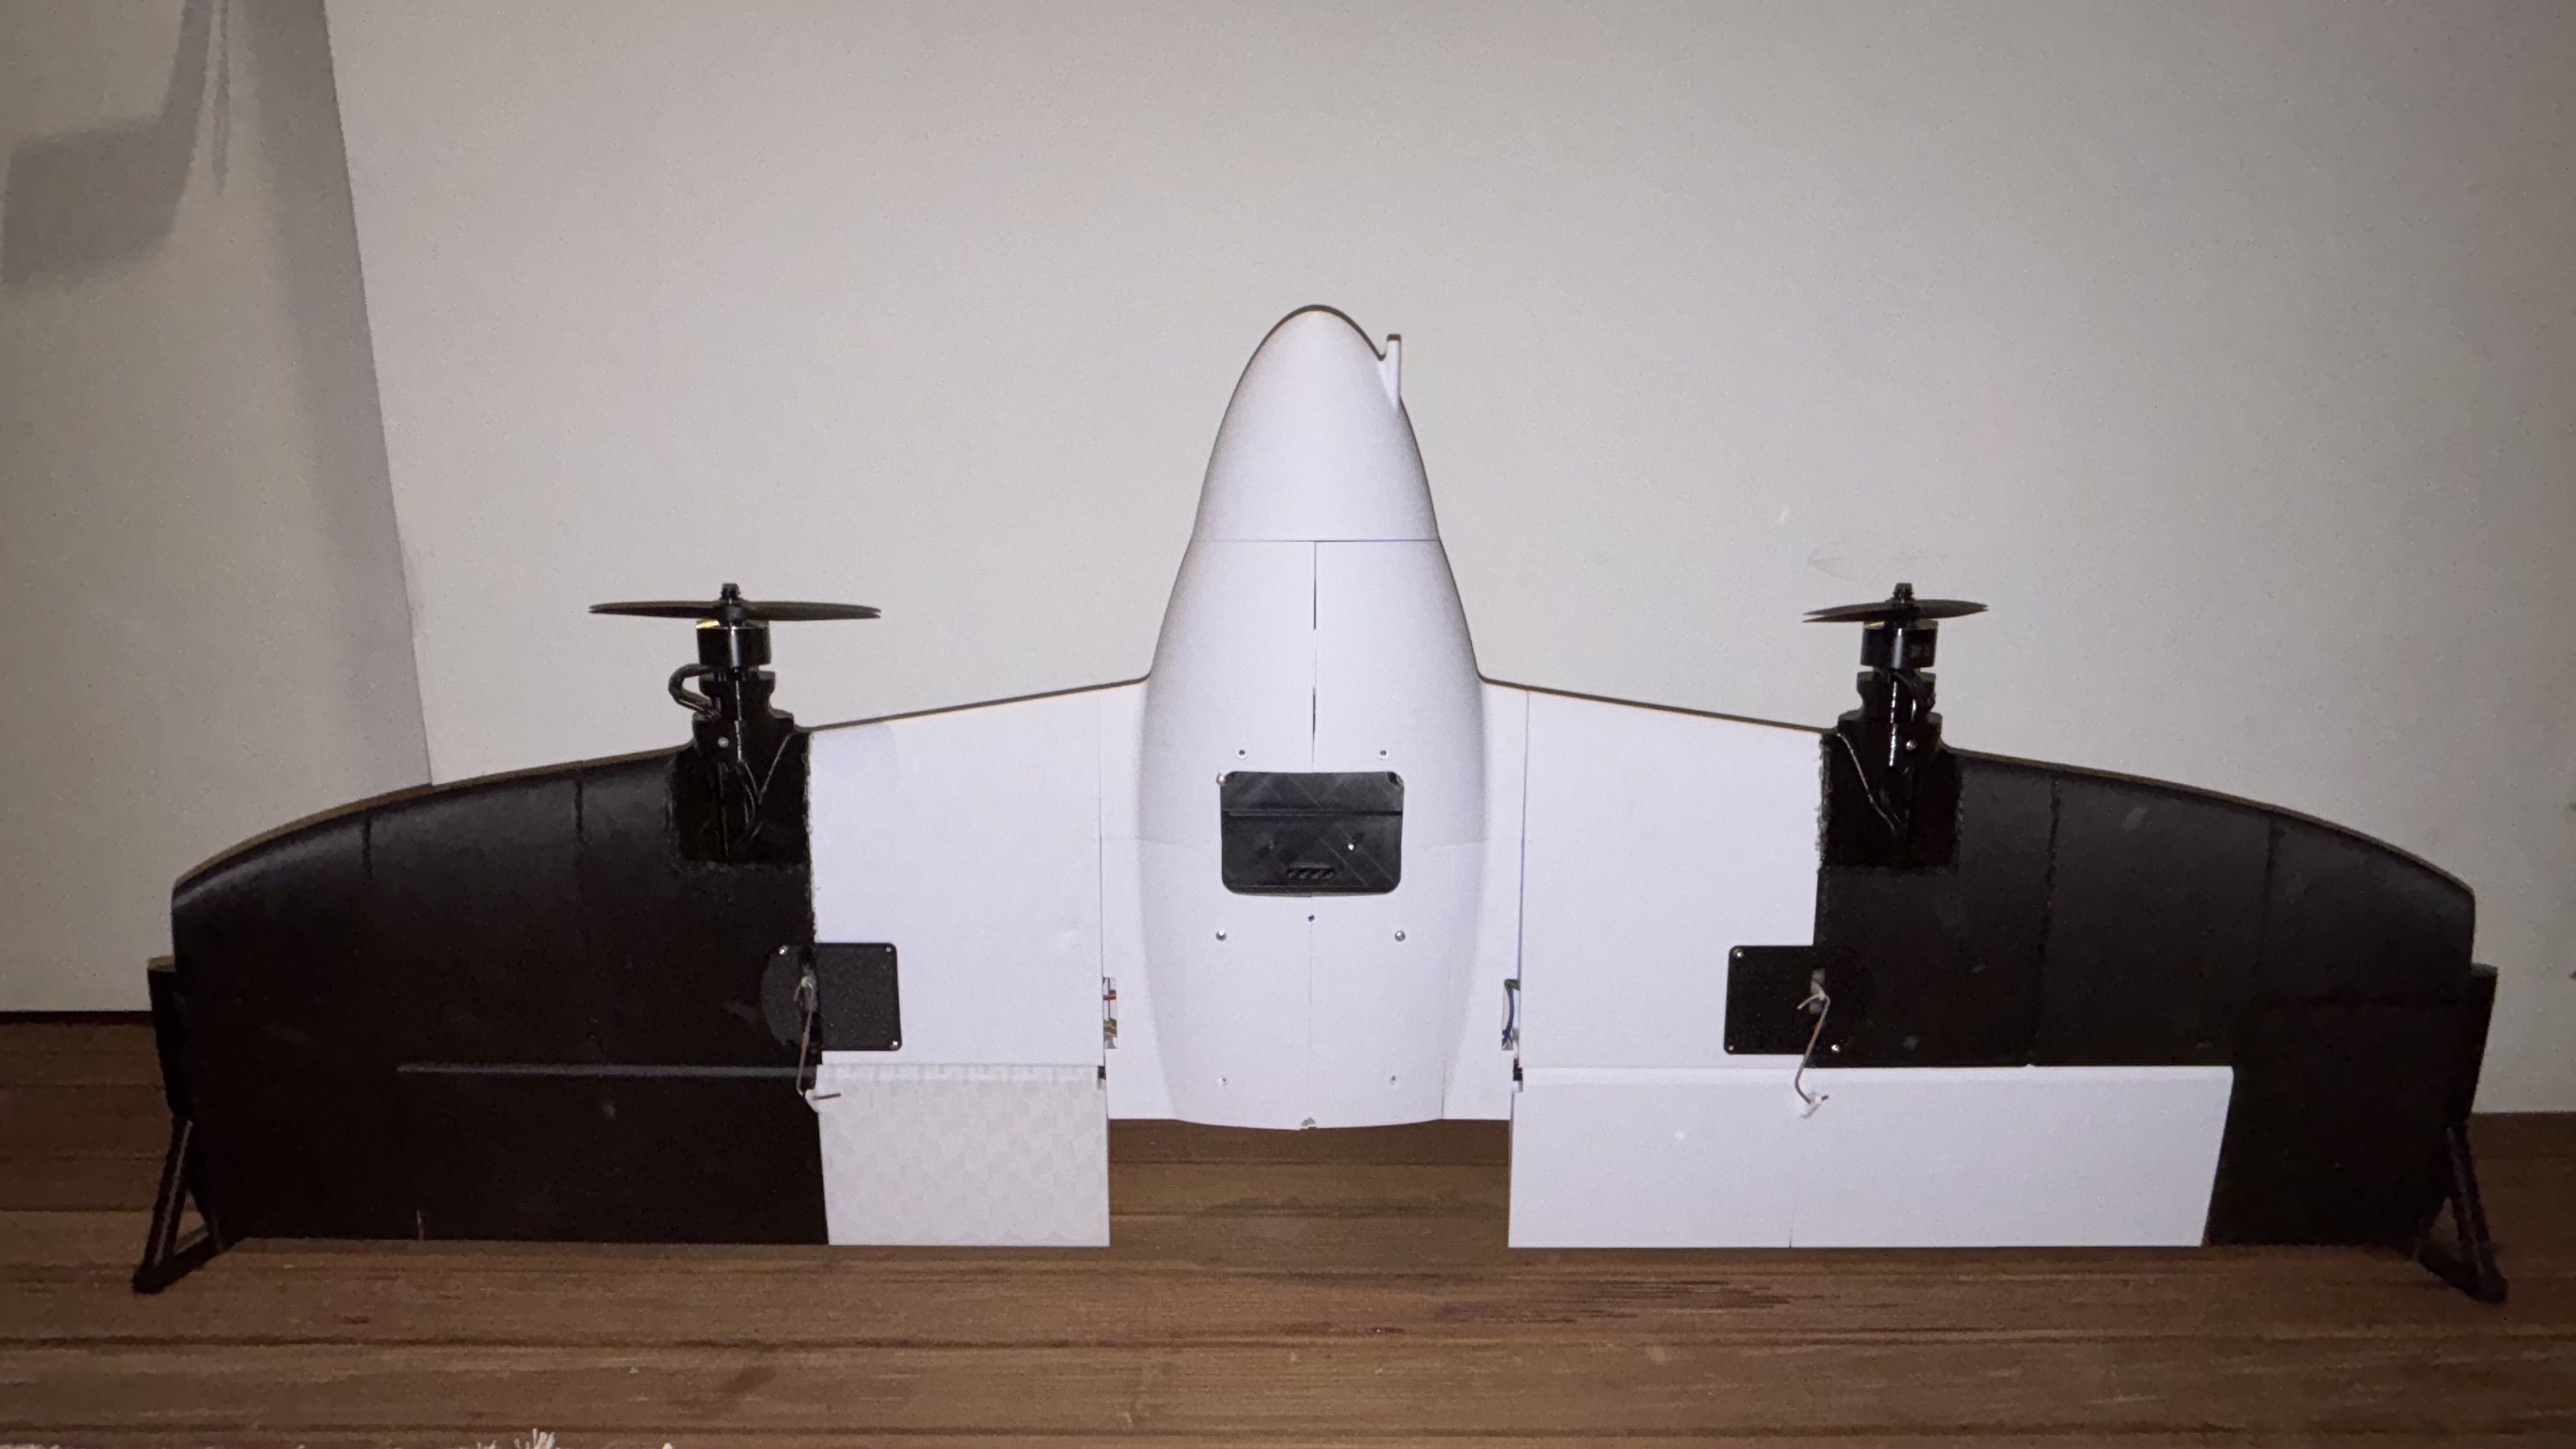
Autonomous Tailsitter UAV

Personal self-funded autonomous UAV project with 1.3m wingspan, designed to stay under 5 kg, with only 2 motors, VTOL capability, and the efficiency, speed, and reliability of a fixed-wing aircraft, capable of remote operations. The frame is completely 3D printed and the project is currently in development. I am now leading flight testing and control tuning with PX4 Autopilot to iterate on autonomous flight dynamics, while also developing a ROS 2 perception and navigation framework based on multi-modal sensor fusion (LiDAR, radar, IR, RGB) for GPS-denied and low-visibility operations.
Semantic 3D Mesh Reconstruction

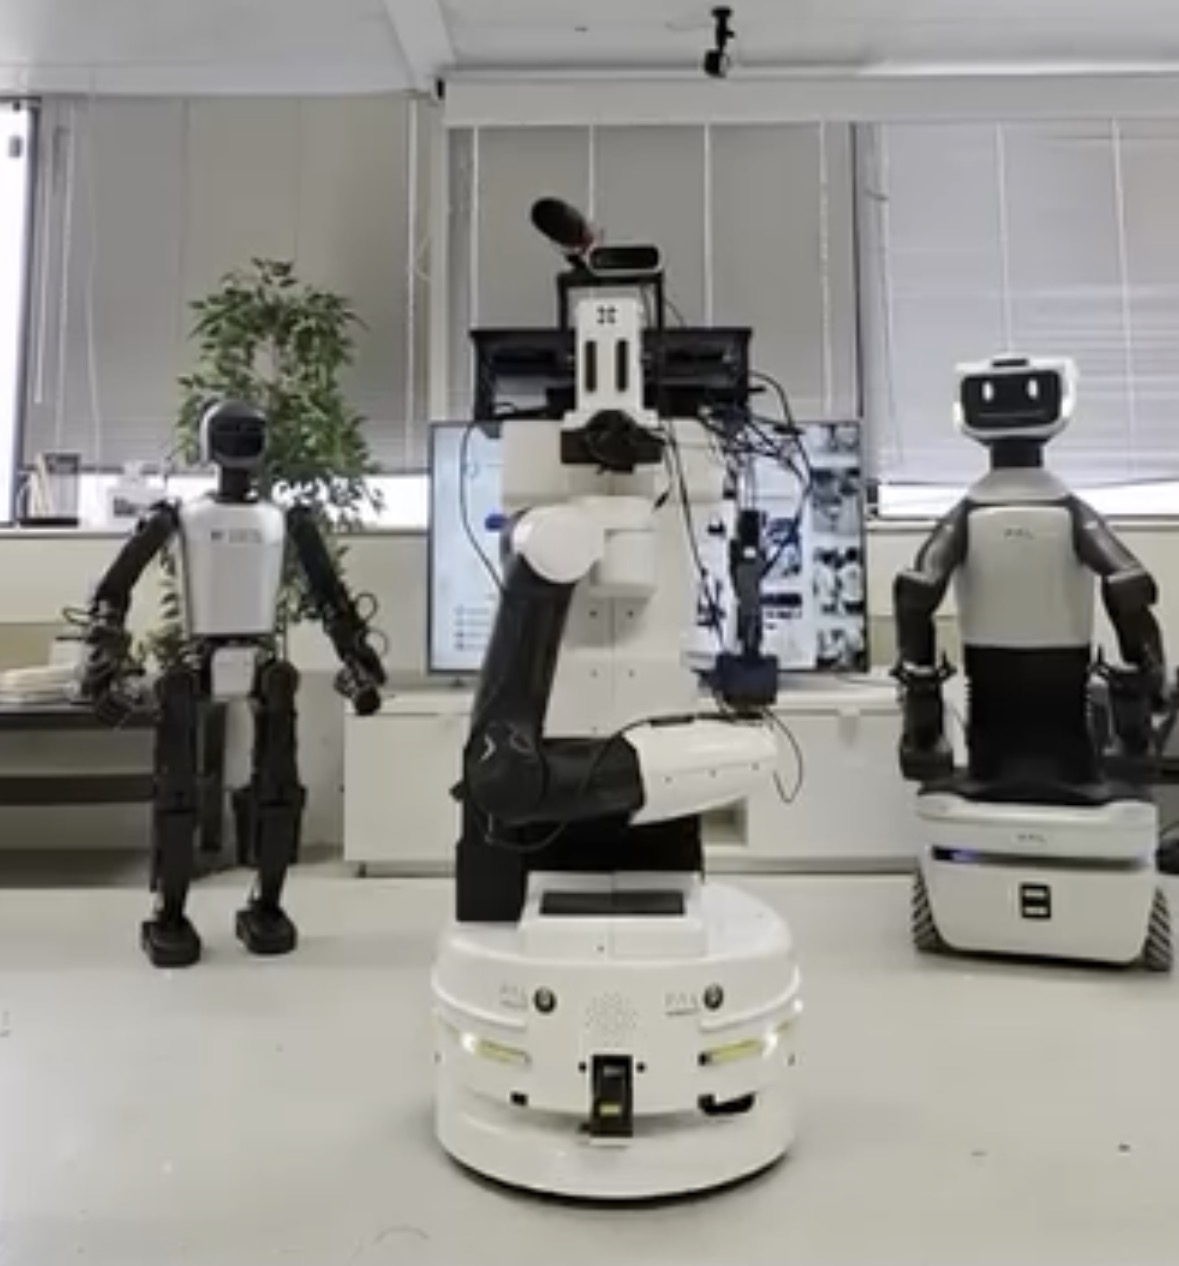
ISR (Institute for Systems and Robotics) Lisbon - SocRob@Home Team

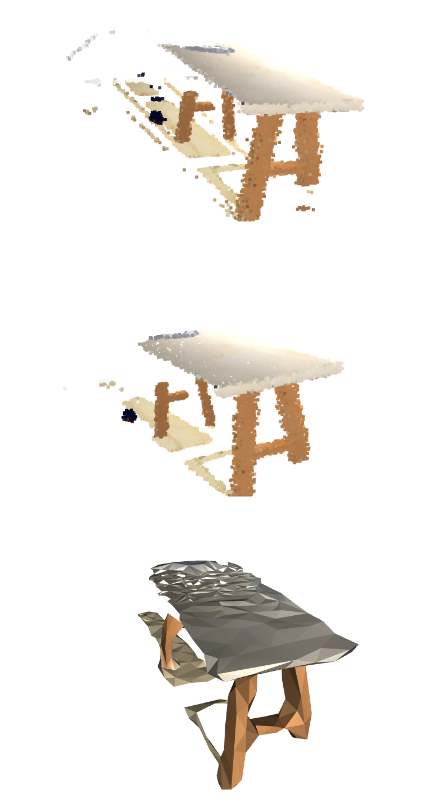
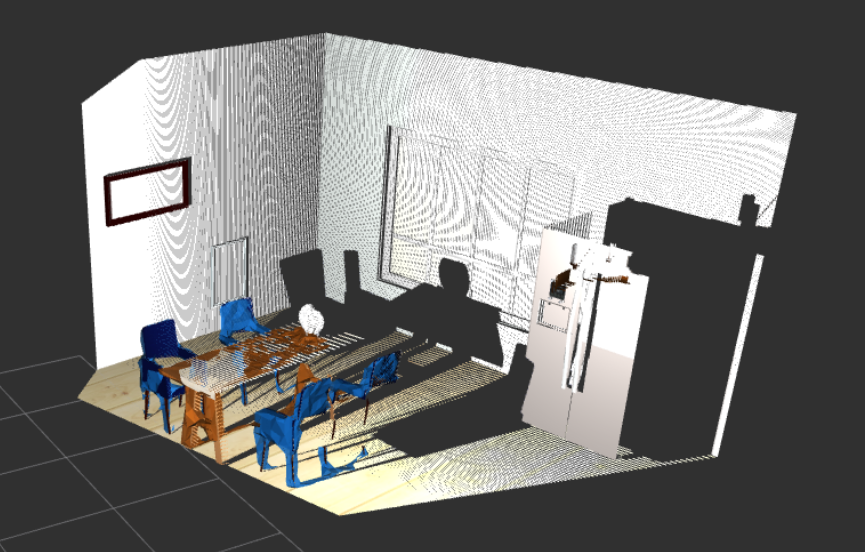
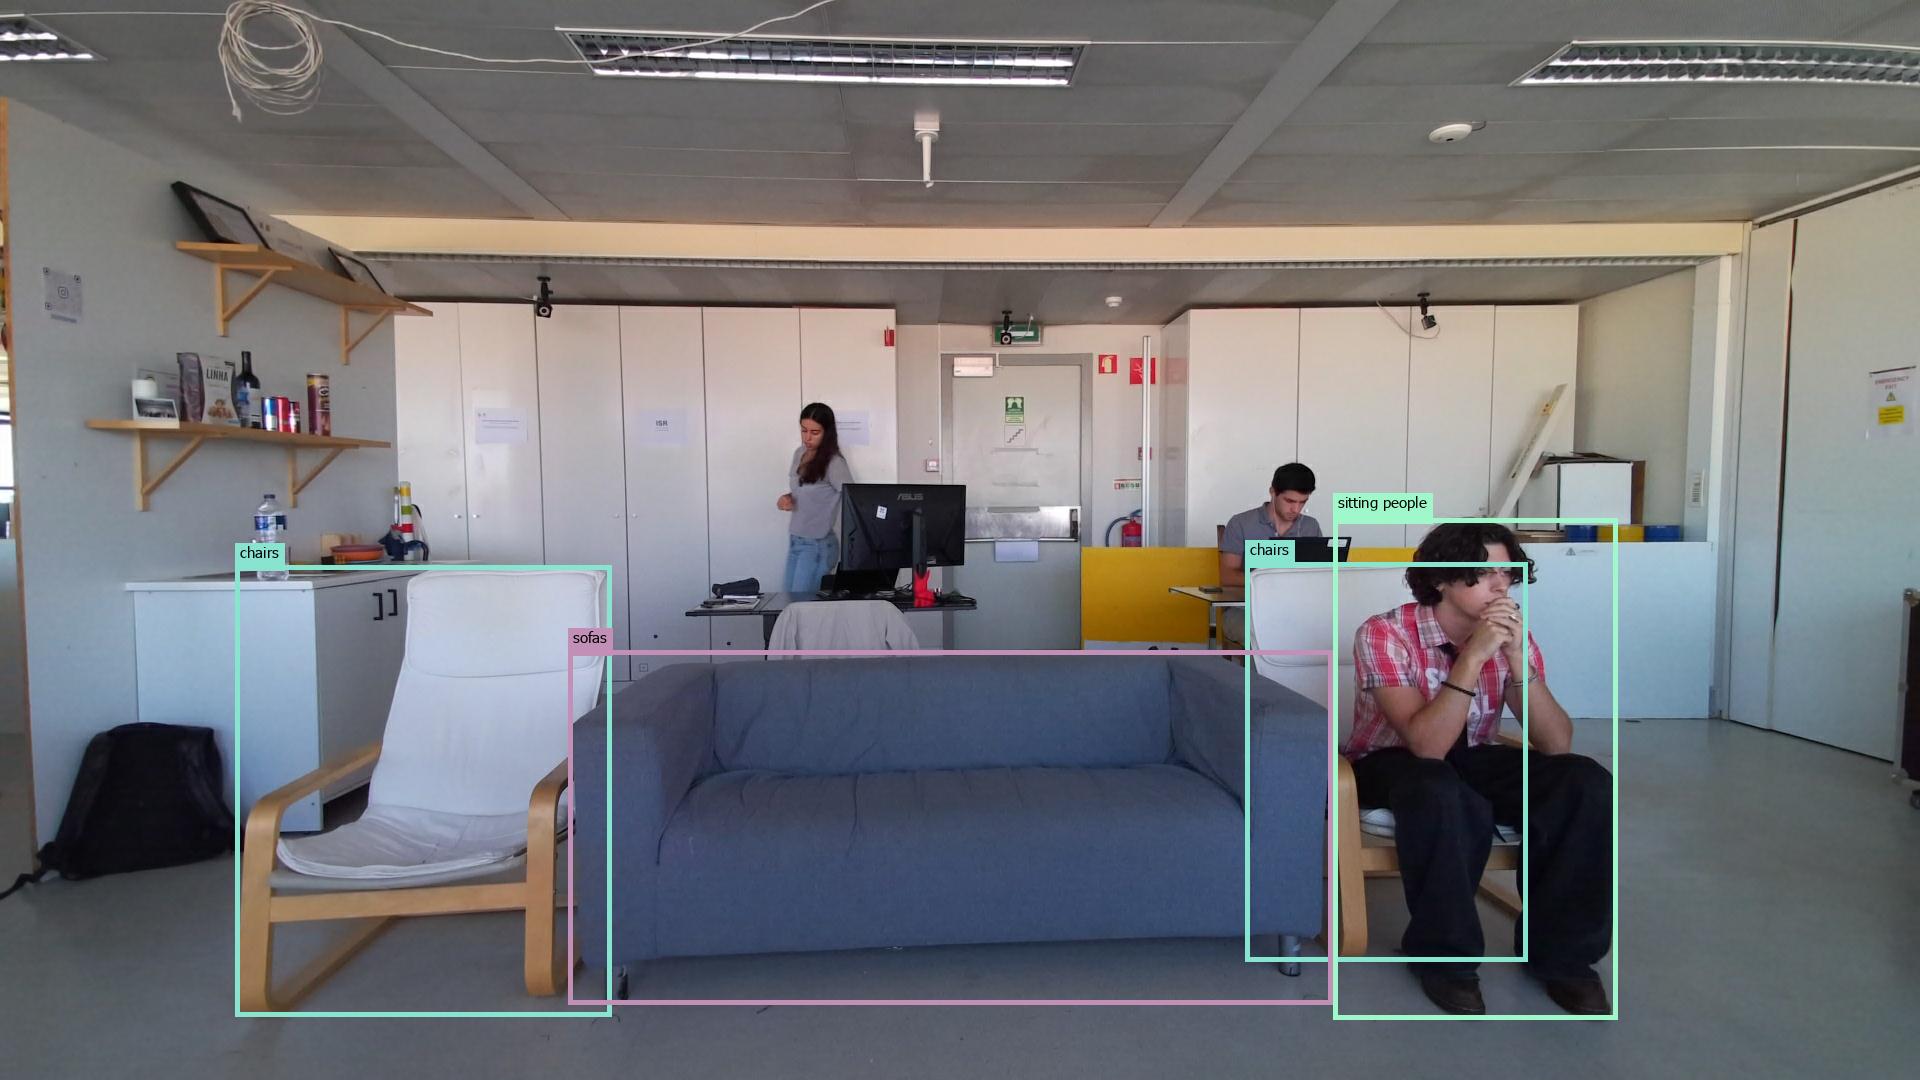
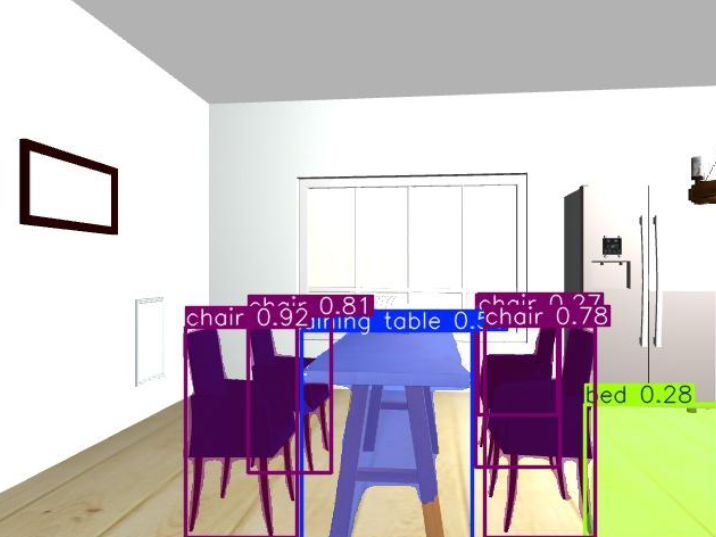
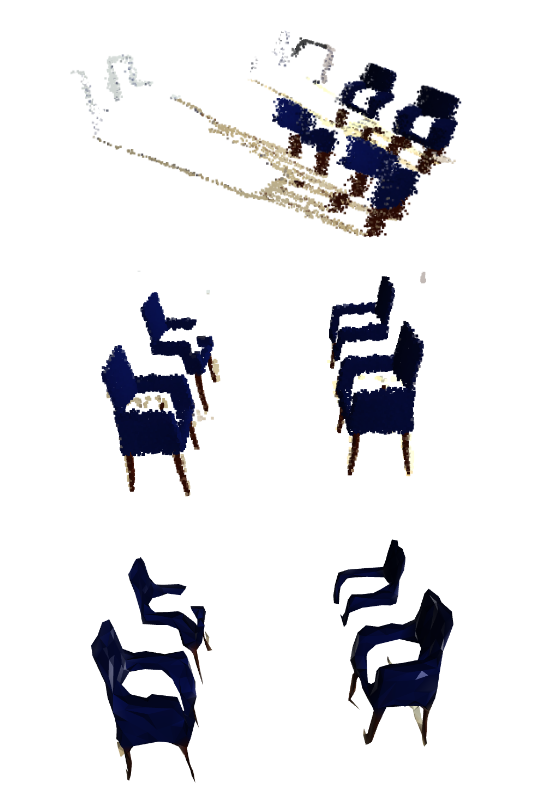
ROS 2 semantic mapping package for service robots, combining a YOLO based pipeline and a SAM3 based version, both validated on real robots. It extracts 3D point clouds from segmented images and reconstructs semantic meshes with Open3D for perception and manipulation tasks in preparation for RoboCup 2026 and euRobin. I also implemented a lightweight VLM interface for the robot's autonomy stack using FastAPI for fast communication with a server in real-time applications.

View project

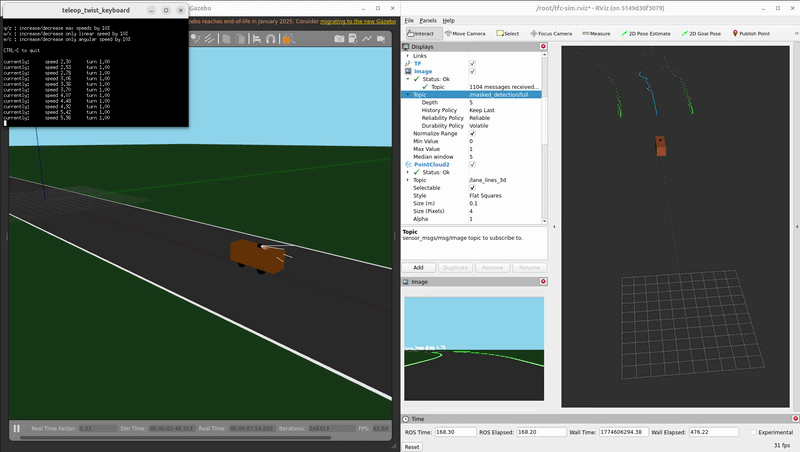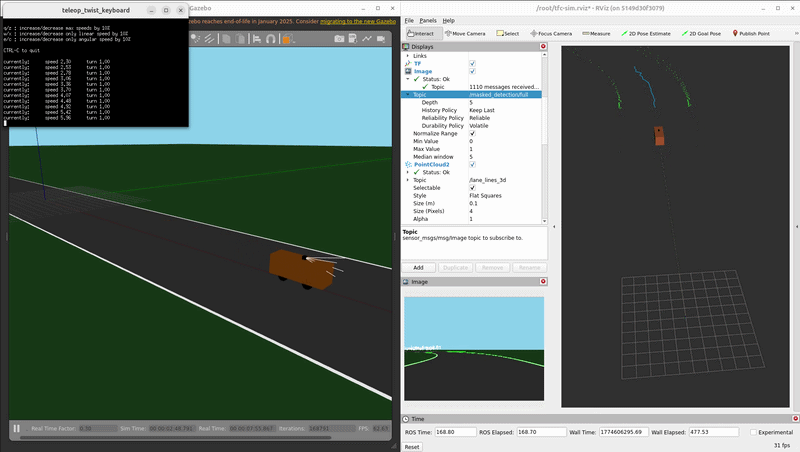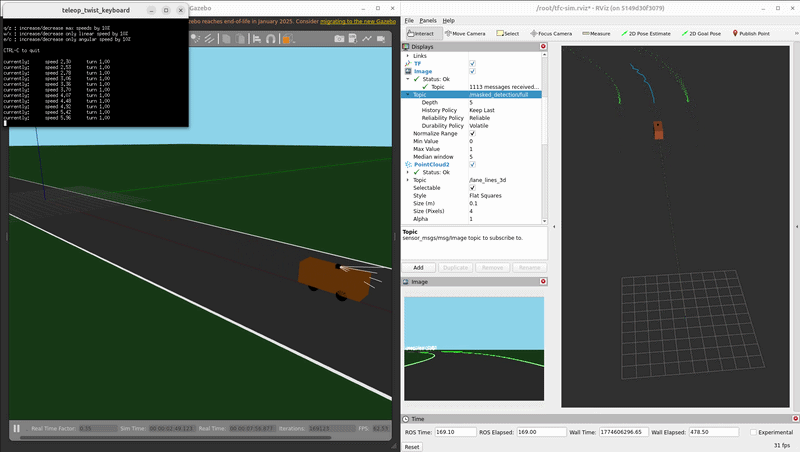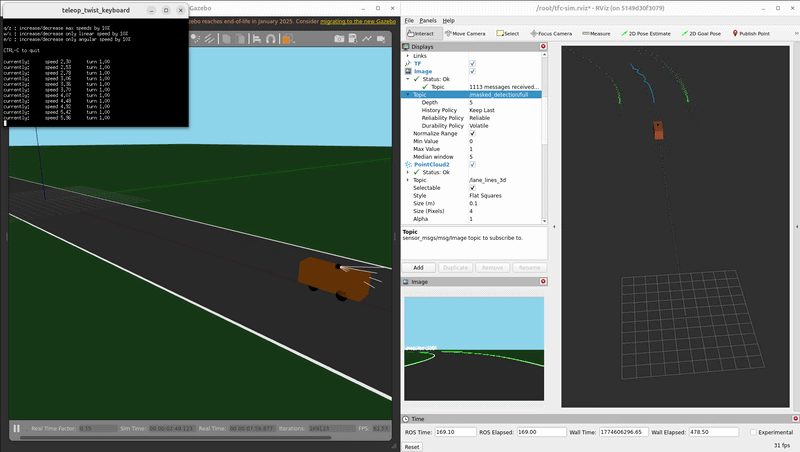
Autonomous stack development and Gazebo Simulation

TFC (Técnico Fuel Cell) - Autonomous Systems Team

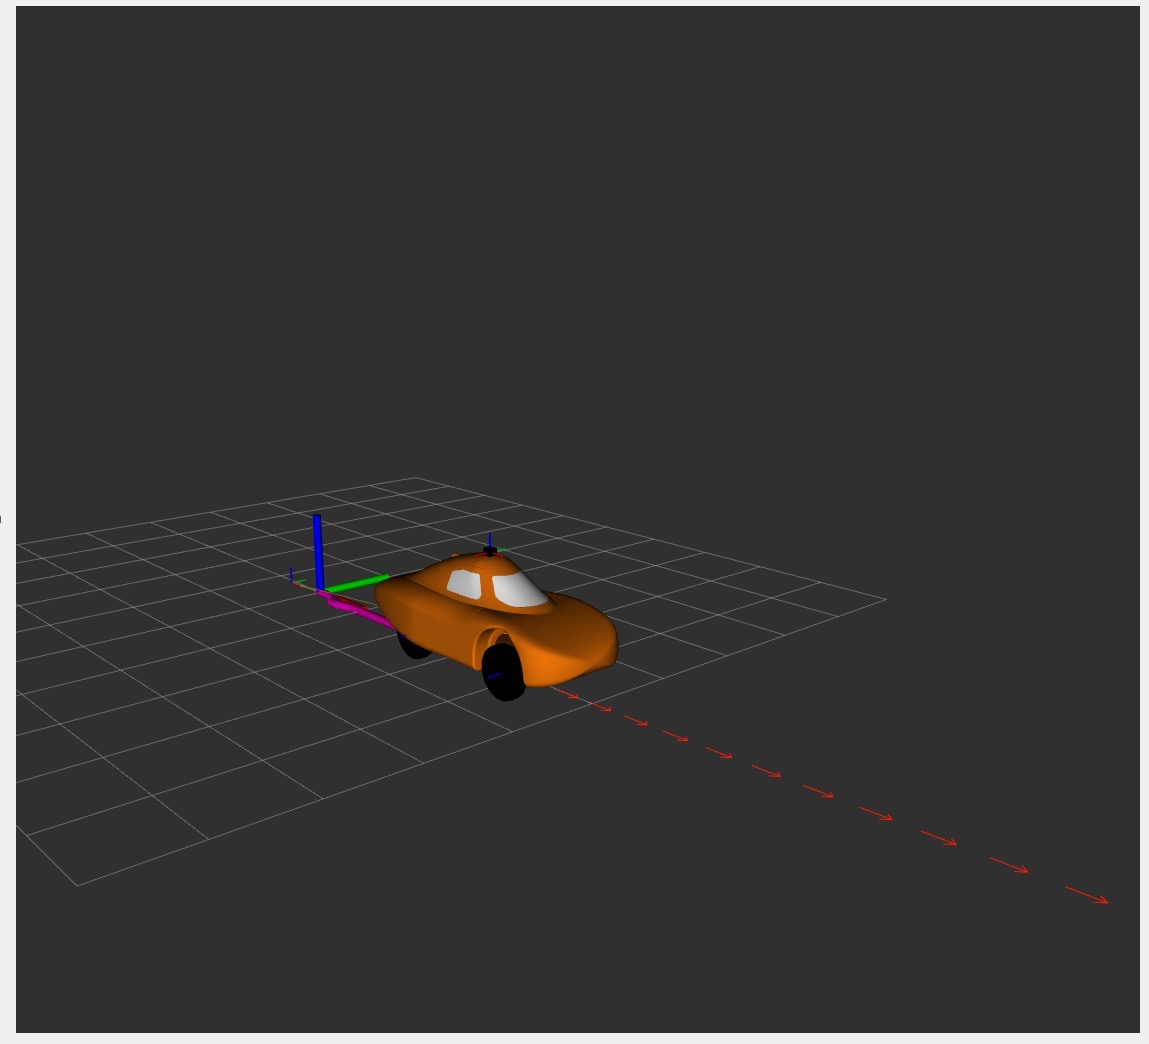
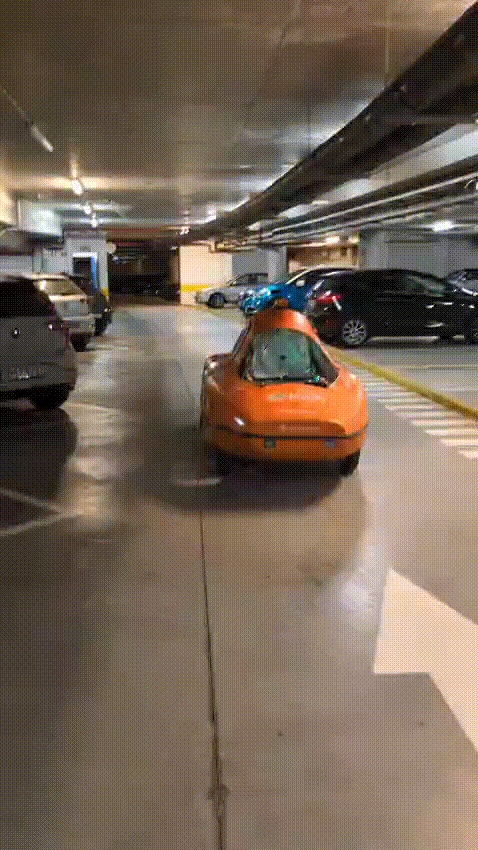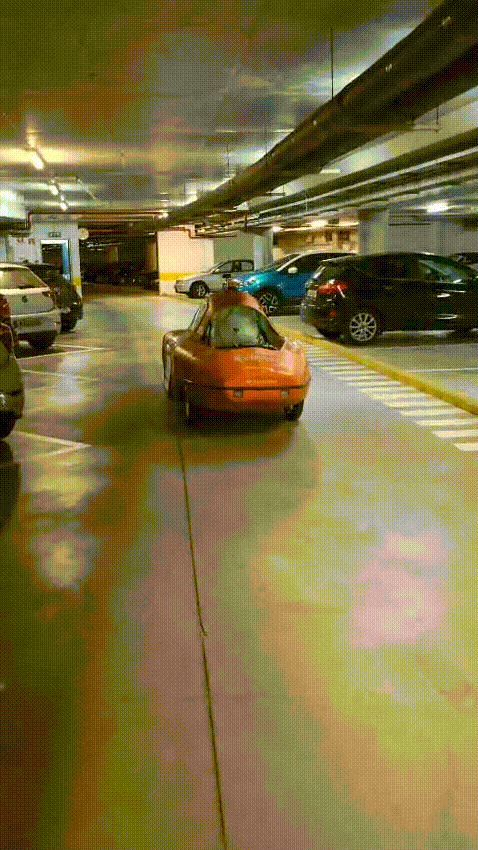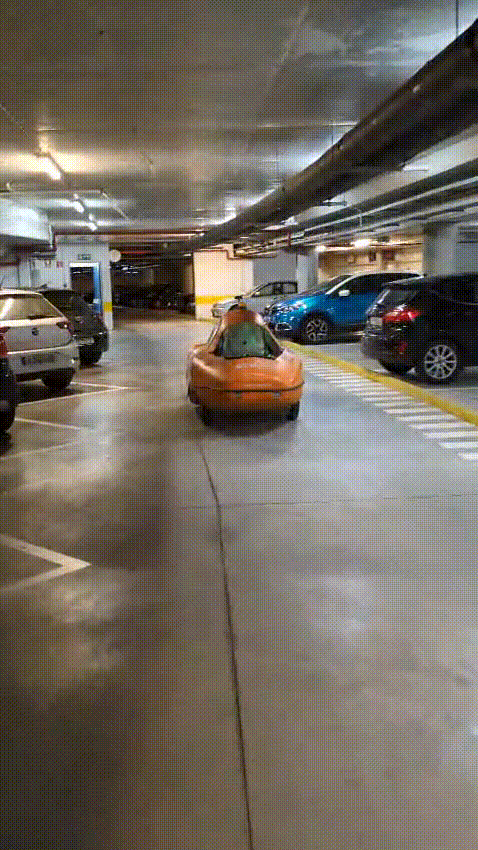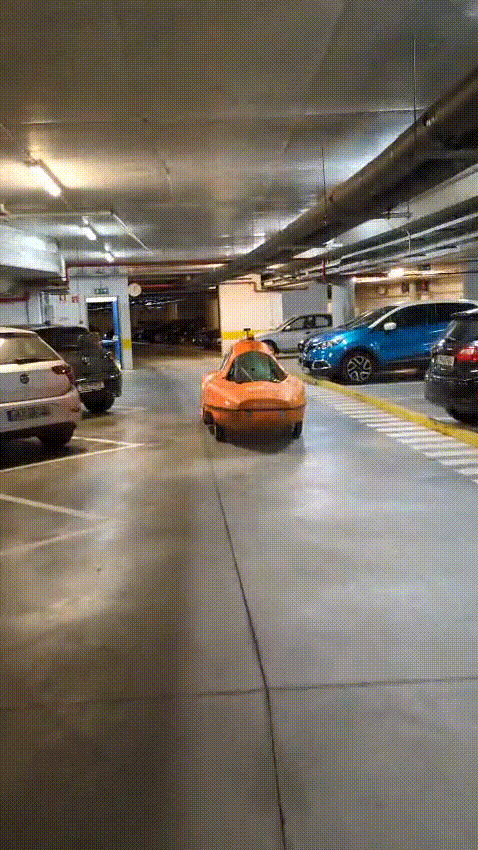
My work included URDF design, Gazebo controllers, detection model implementation and training (with YOLO), sensor fusion and calibration, SLAM optimization, and MPC tuning. I was also responsible for the complete development of the Gazebo simulation, designed to model sensors, actuators, and the racing track to validate the car's autonomy stack in preparation for Shell Eco Marathon 2026 in Poland.

More Info

Drone Prototyping

AeroTéc ATLAS - Systems Team

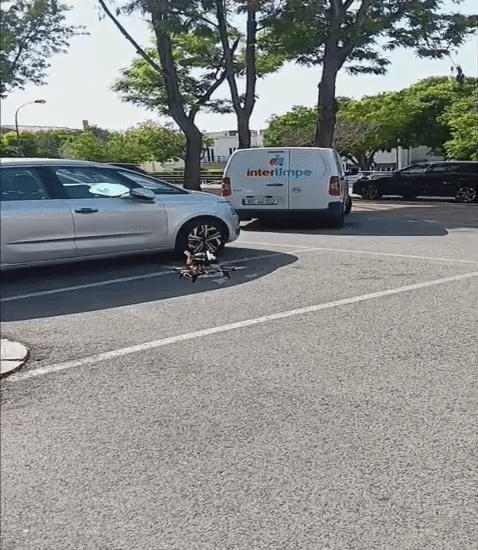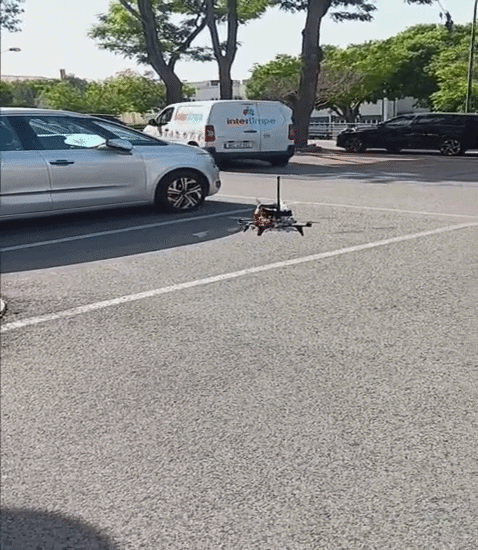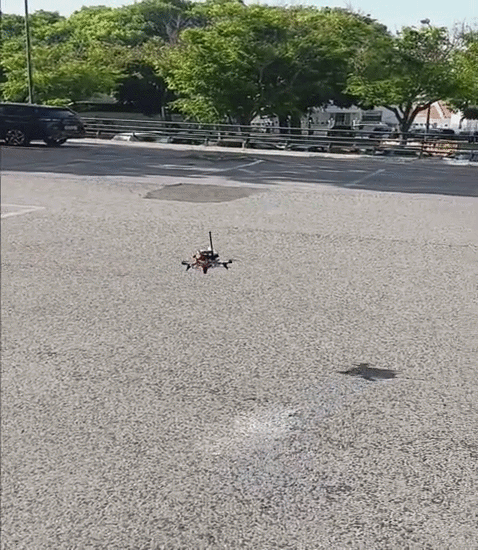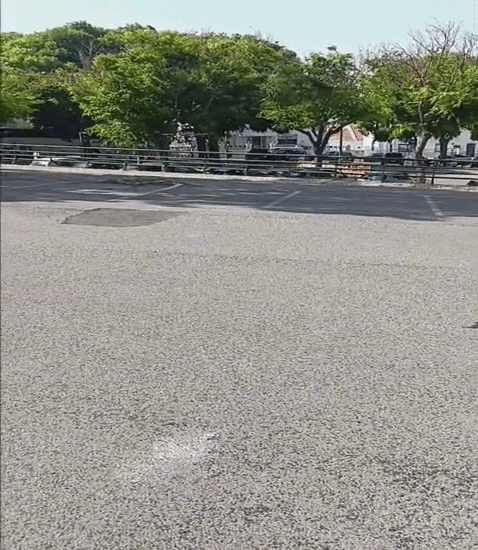
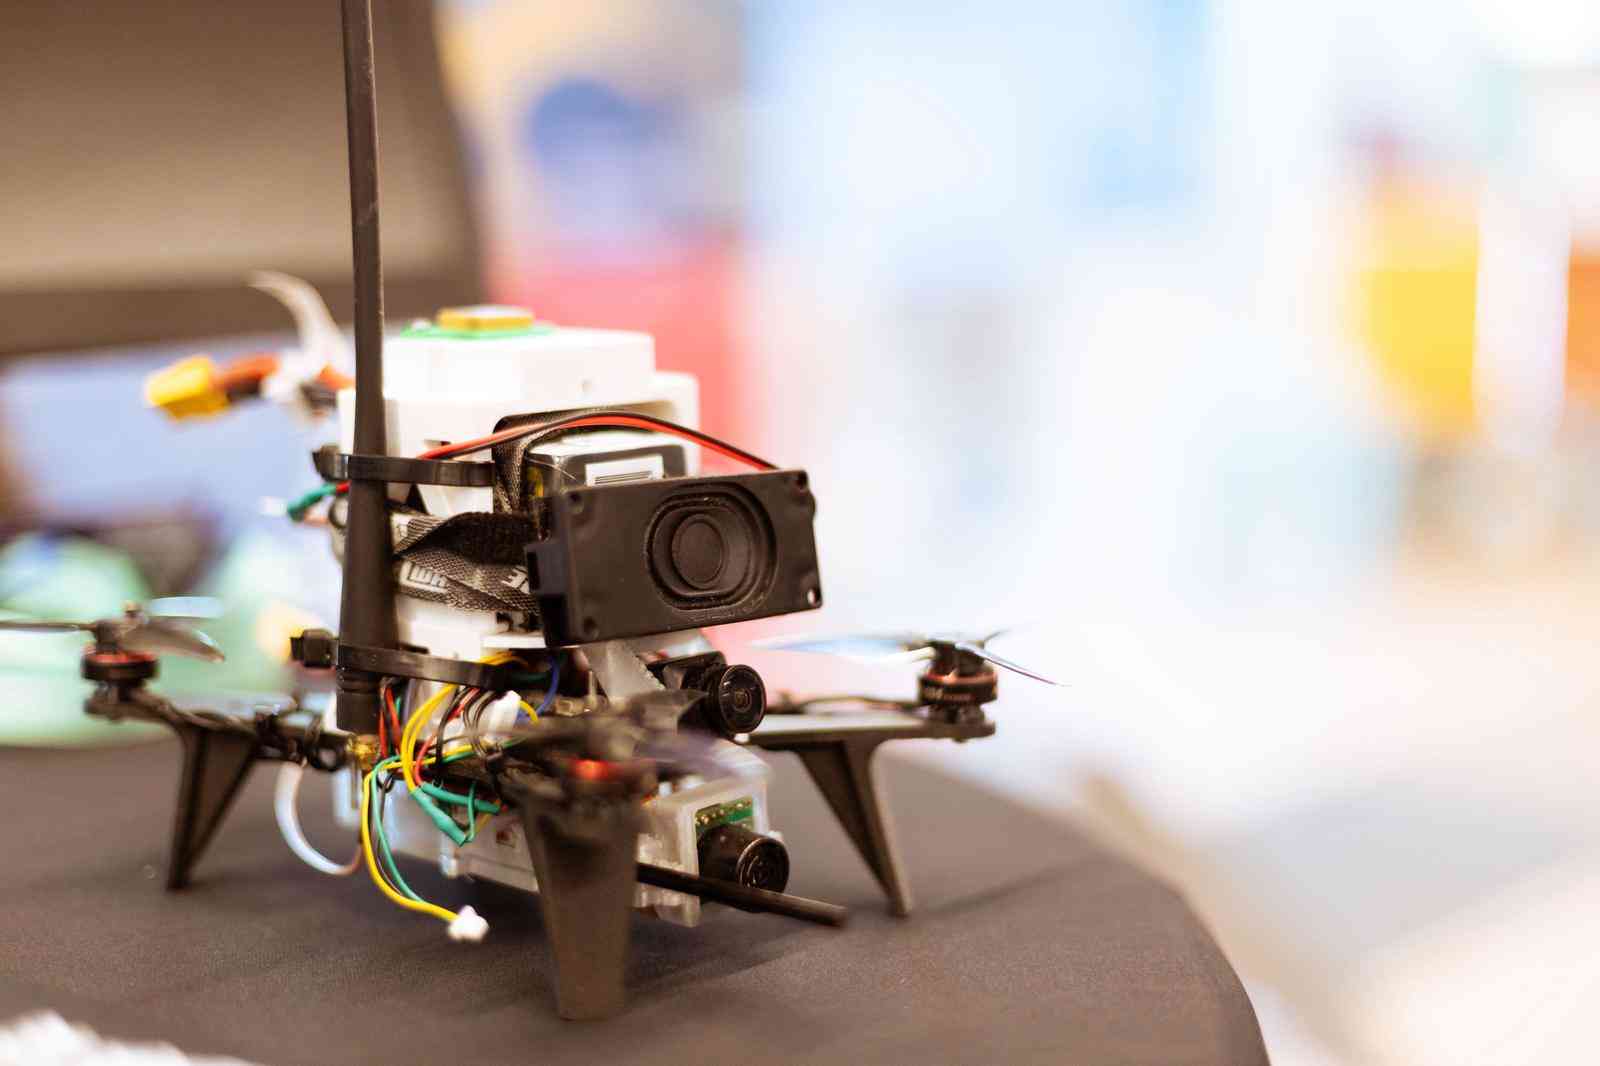
Quadrotor design, from avionics architecture to CAD and manufacturing. The drone was designed for autonomous rescue applications, detecting a person and establishing communication with support services.

More Info

Prototyping Projects

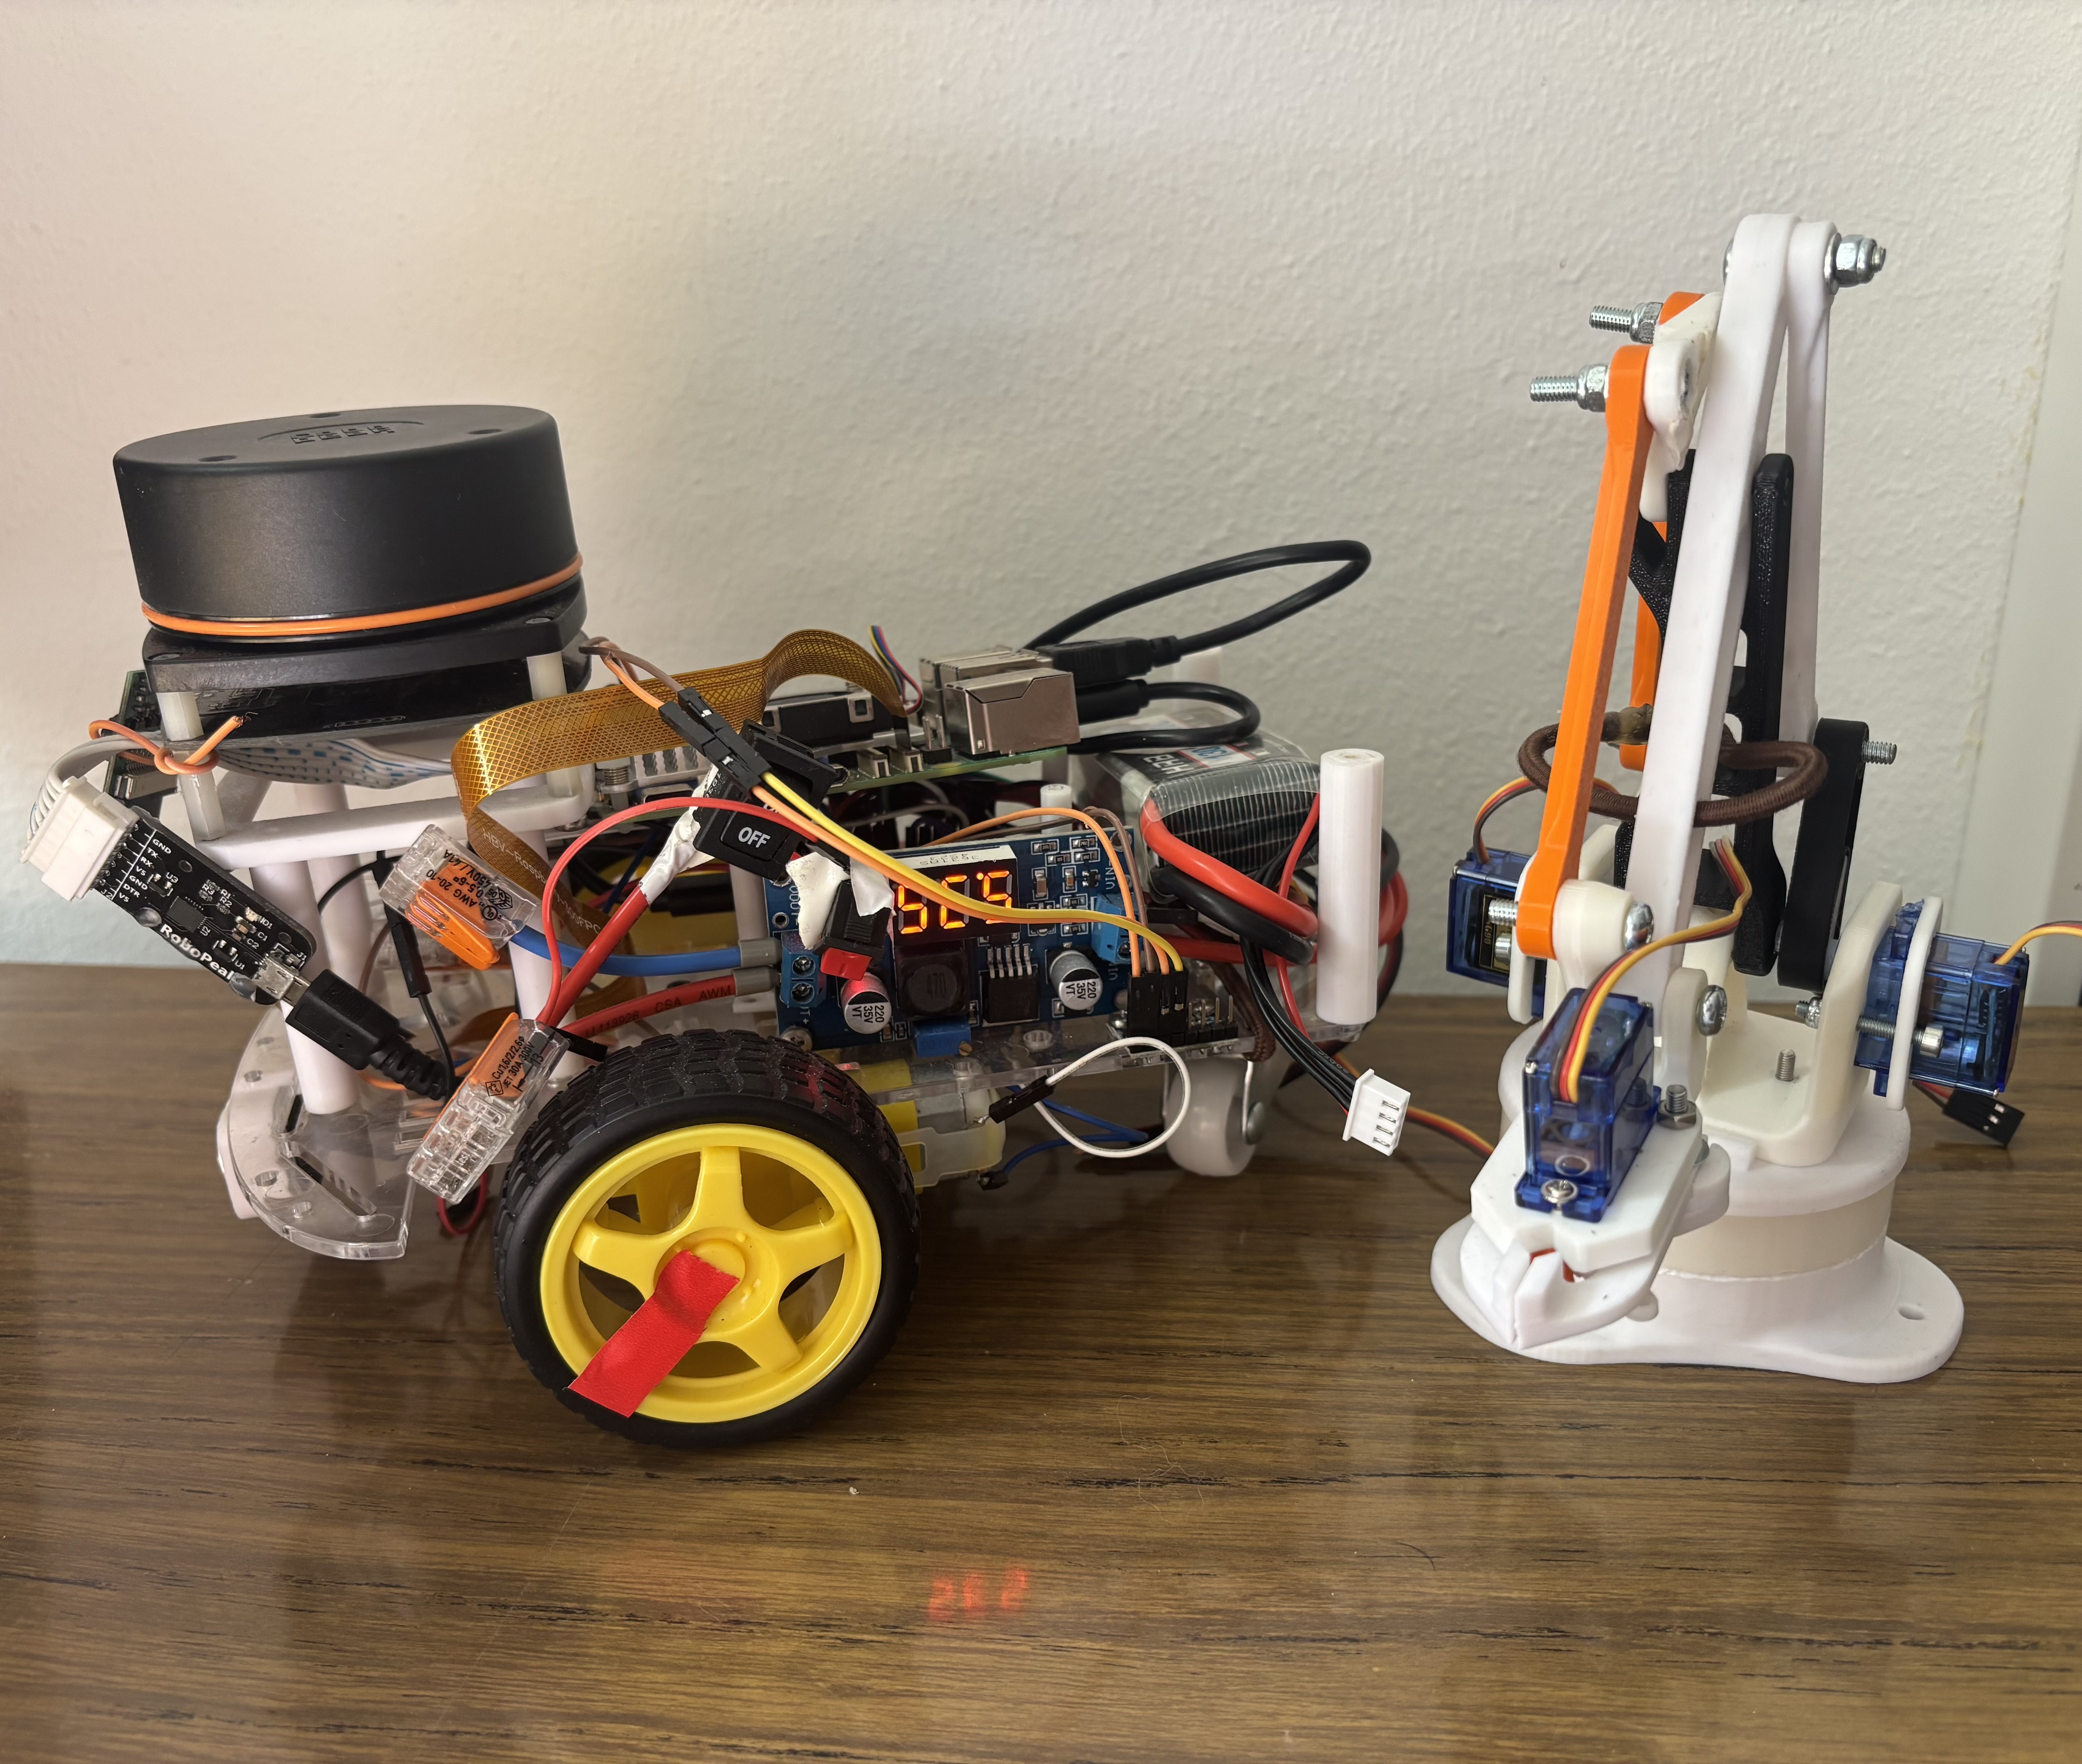
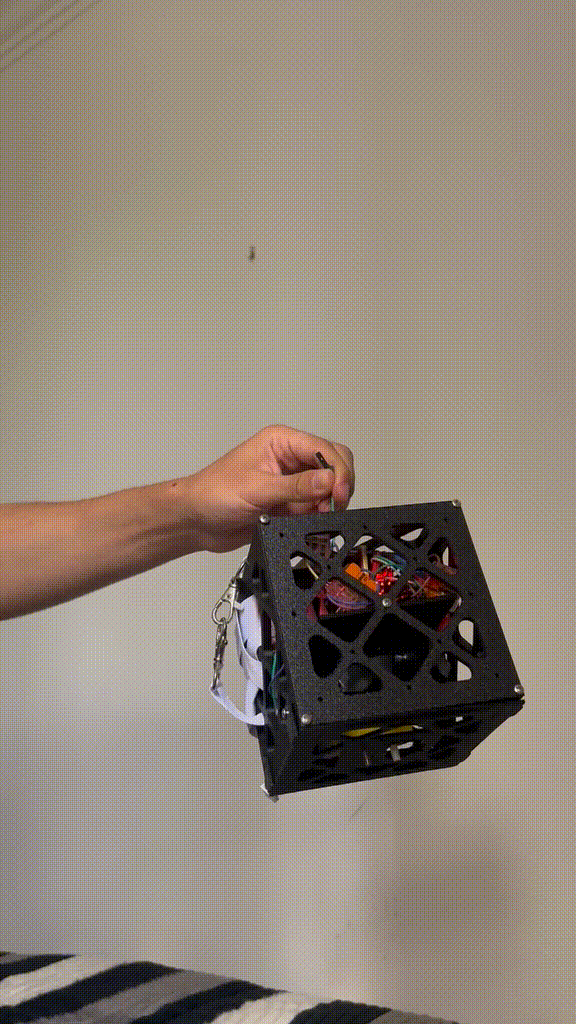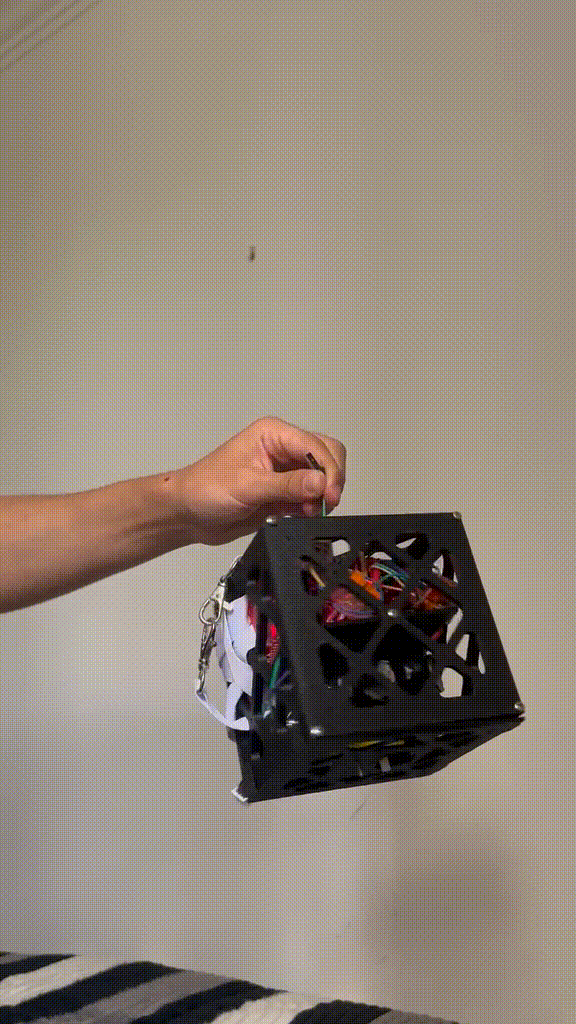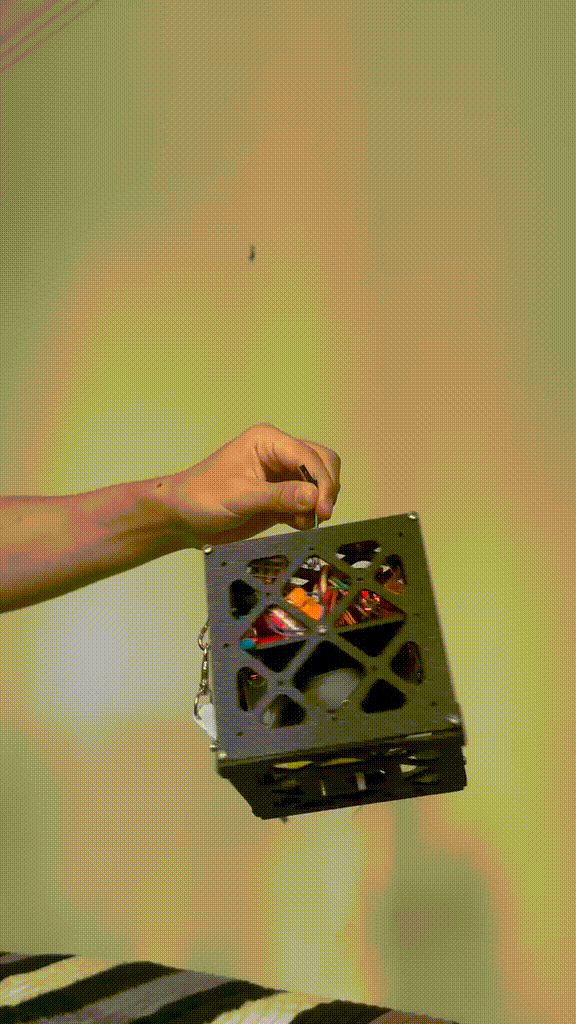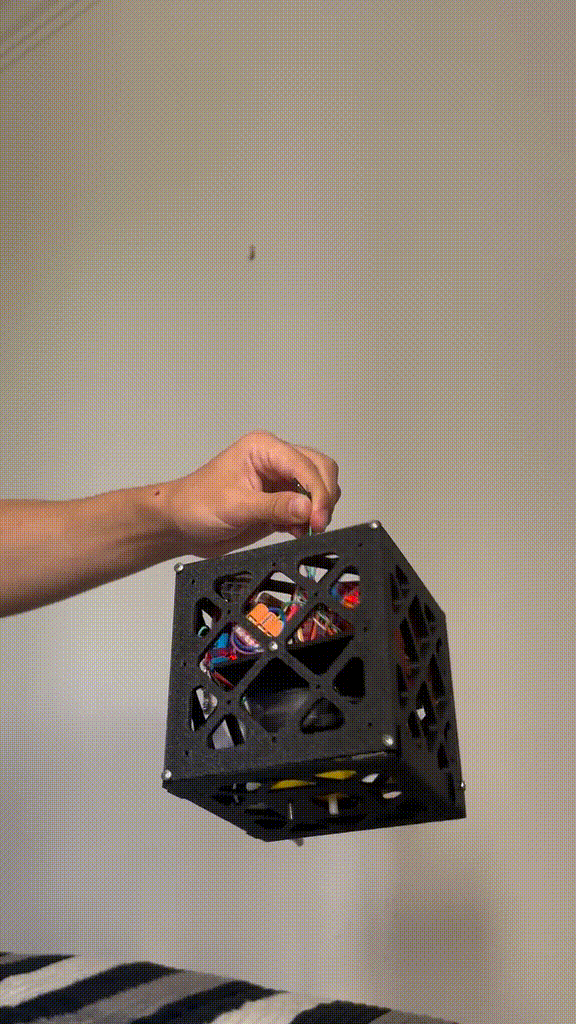
Personal projects focused on designing prototypes using 3D printing, power electronics, sensors, embedded programming (C/C++), and ROS 2. These include a small-scale AMR, a robotic arm, and a 1U satellite.

View project